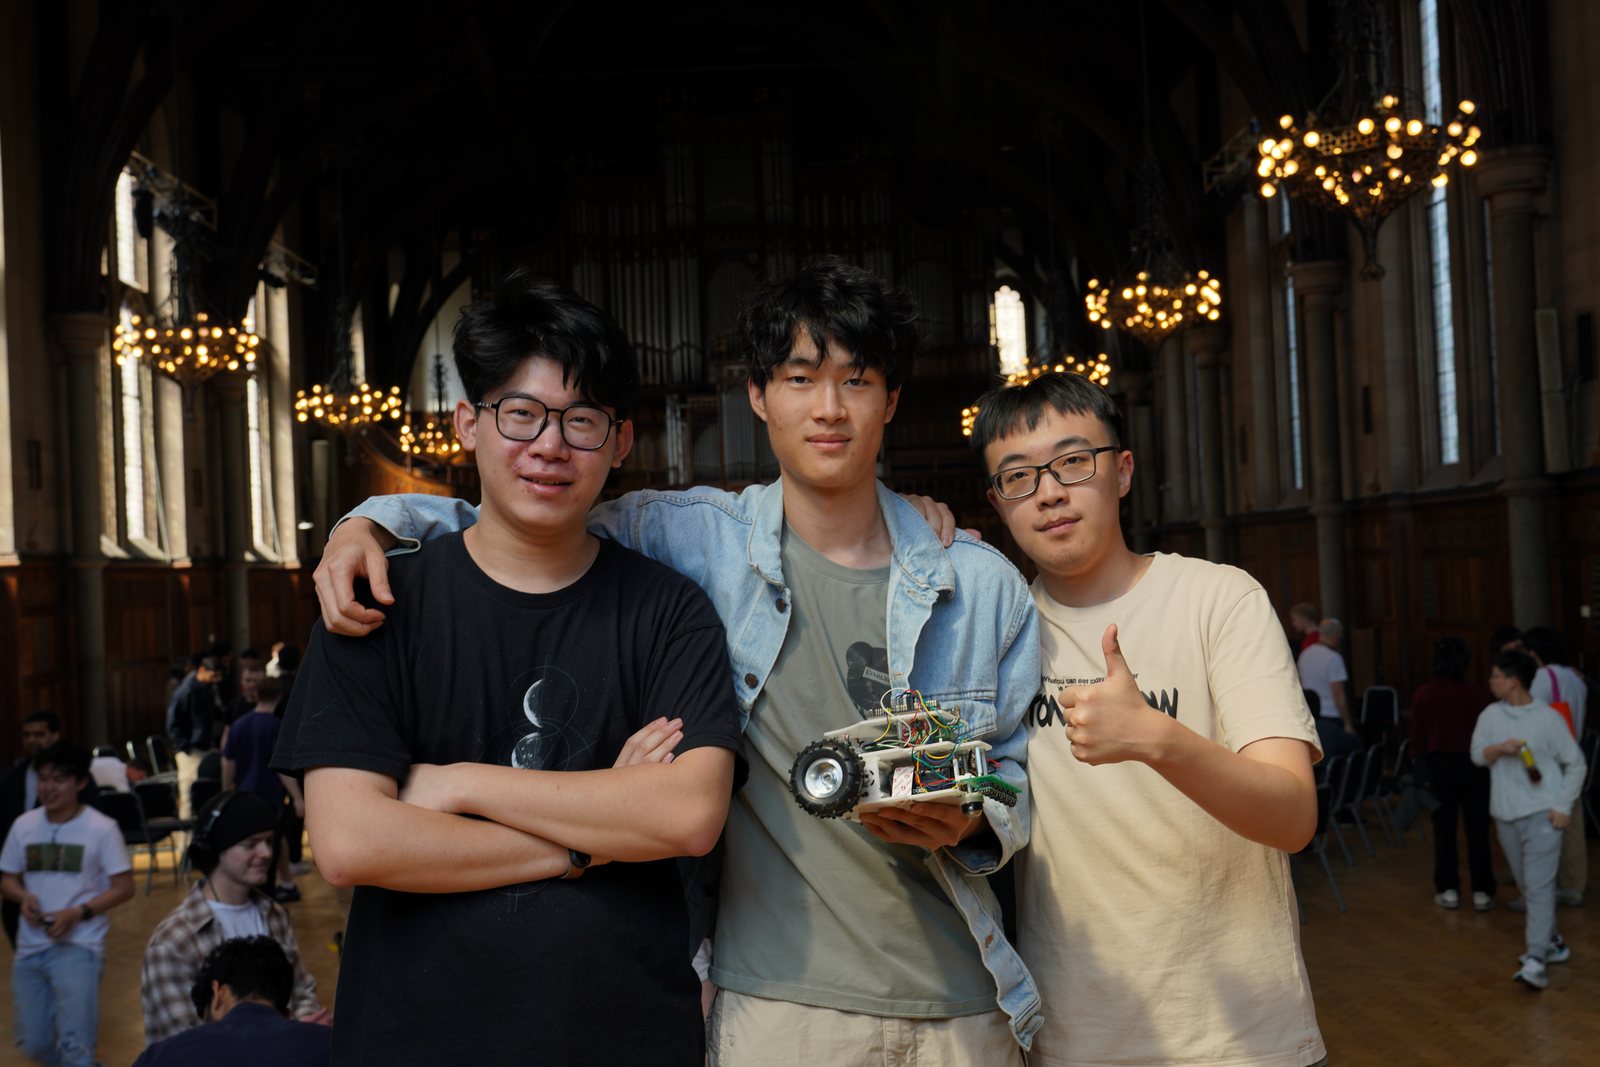
Overview
A year-long project to design and build a fast, autonomous line-following robot ("the buggy") on an STM32F401RE Nucleo board. The buggy tracks a white line along a defined course using a custom sensor array, real-time embedded firmware, and closed-loop PID control, developed for an end-of-year competition. The work spanned motor characterisation, sensor selection, PCB design, and control-system development, integrating hardware, firmware, and control into a single system.
View on GitHub